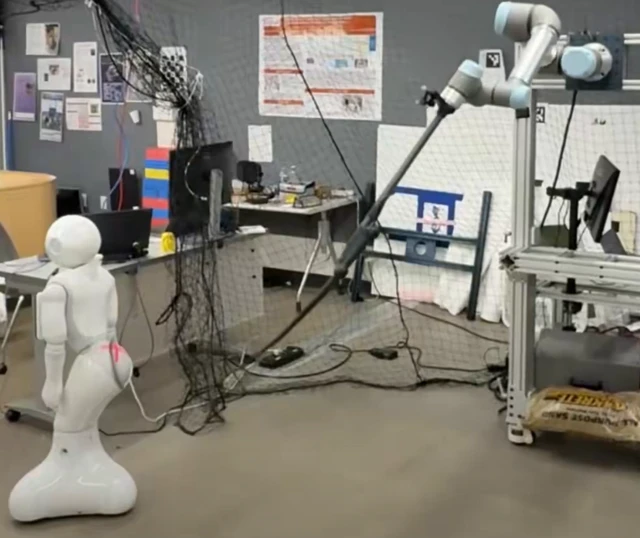
In what can only be described as a rather awkward milestone for inter-robot relations, researchers at Carnegie Mellon University have successfully trained a robotic arm to give a Pepper robot a proper thrashing with a whip.
Before you call for a robot rights tribunal, rest assured this isn’t just gratuitous metallic bullying; it’s a masterclass in DeformX—a sophisticated new simulation framework designed to crack the complex physics of ‘deformable objects’ like ropes, cables, and, evidently, leather whips. The project focuses on high-fidelity ‘sim-to-real’ transfer, ensuring that what works in the digital world translates perfectly to the physical one. Judging by the precision on display, Pepper’s real-world counterpart might want to start looking into a bit of hazard pay.